Robotclub Malaysia › Ecosystem › AI Sapiens
AI Sapiens
An open source humanoid platform for Physical AI, built on DYNAMIXEL Q actuators.
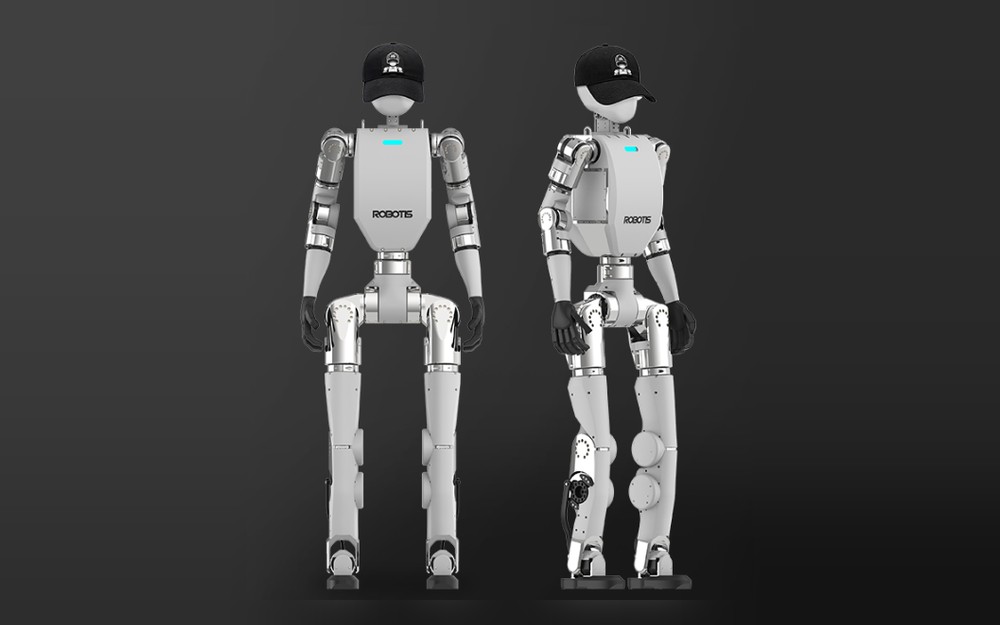
Open source humanoid platform
Overview
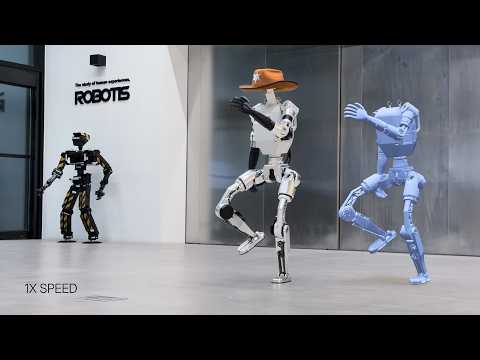
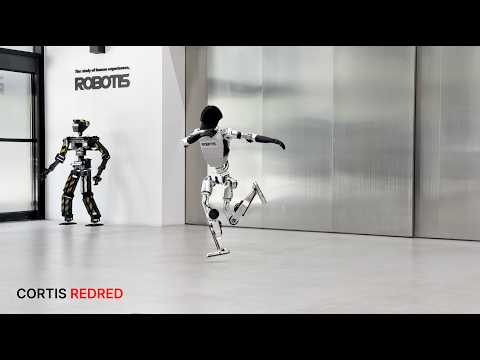
AI Sapiens is the ROBOTIS humanoid platform for Physical AI. It is built on DYNAMIXEL Q actuators and designed for developing motion, learning and control on real hardware.
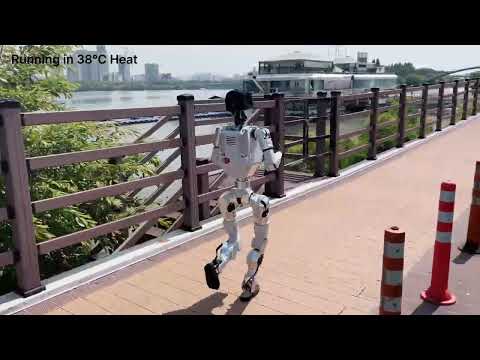
The aim is that policies trained with imitation learning and reinforcement learning can be deployed on the physical robot instead of staying in simulation.
- 23Degrees of freedom
- QDYNAMIXEL actuators
- OpenSource code and materials
- IL + RLLearning methods
Key Features
Platform for Physical AI
Documentation, simulation and control resources for training policies and testing them on the real robot.
Fully open source
Code and learning materials are published so developers can fork and extend them.
Powered by DYNAMIXEL Q
Uses ROBOTIS quasi direct drive actuators, which ROBOTIS describes as suited to dynamic balancing and manipulation.
23 DOF full body motion
Head, arms, legs and waist are covered for locomotion and upper body tasks.
Models & Specifications
Key facts
| Item | Detail |
|---|---|
| Robot type | Humanoid |
| Degrees of freedom | 23 (head, arms, legs, waist) |
| Actuators | DYNAMIXEL Q (quasi direct drive) |
| Learning methods | Imitation learning, reinforcement learning |
| Deployment | Policies trained in simulation can be moved to real hardware |
| Software | Open source: repositories, simulation and tutorials |
Where it fits
- Locomotion and upper body tasks
- Dynamic balancing and manipulation