Robotclub Malaysia › Motor Series › Q Series
Q Series
Actuators for humanoids, designed for strong torque and shock absorption.
Q Motors
Press See more details on a motor to open its full page, or see the full list of all models.
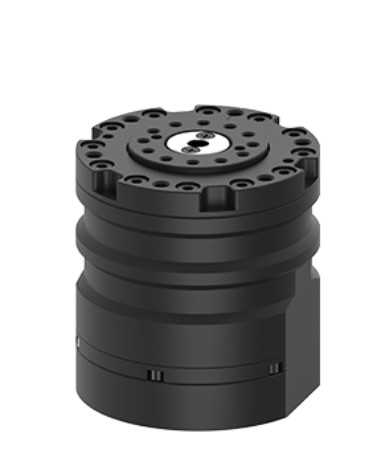
QC060
200 W quasi direct drive humanoid actuator, 10.6 N·m continuous, 30.0 N·m peak.
See more details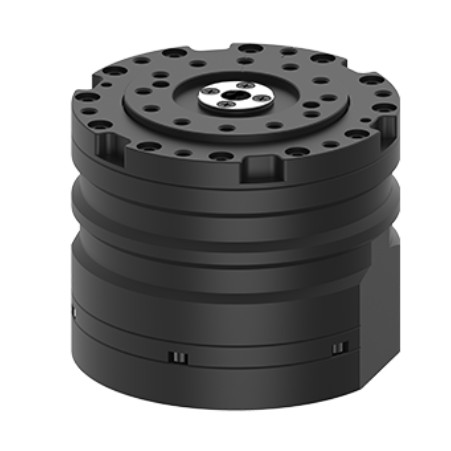
QC080
240 W quasi direct drive humanoid actuator, 24.2 N·m continuous, 72.6 N·m peak.
See more details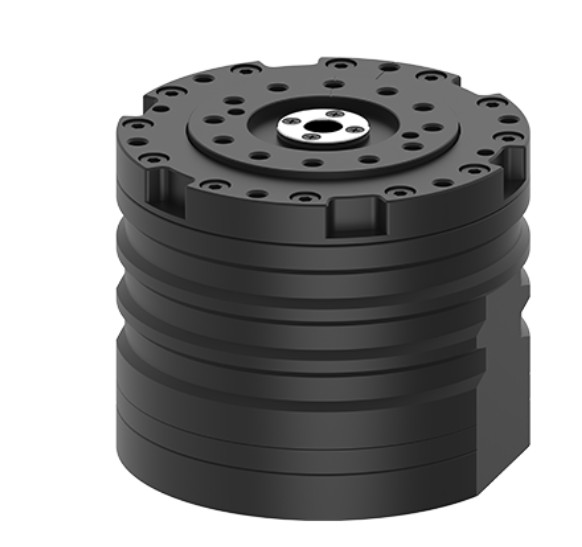
QC100
430 W quasi direct drive humanoid actuator, 51.6 N·m continuous, 166.2 N·m peak.
See more details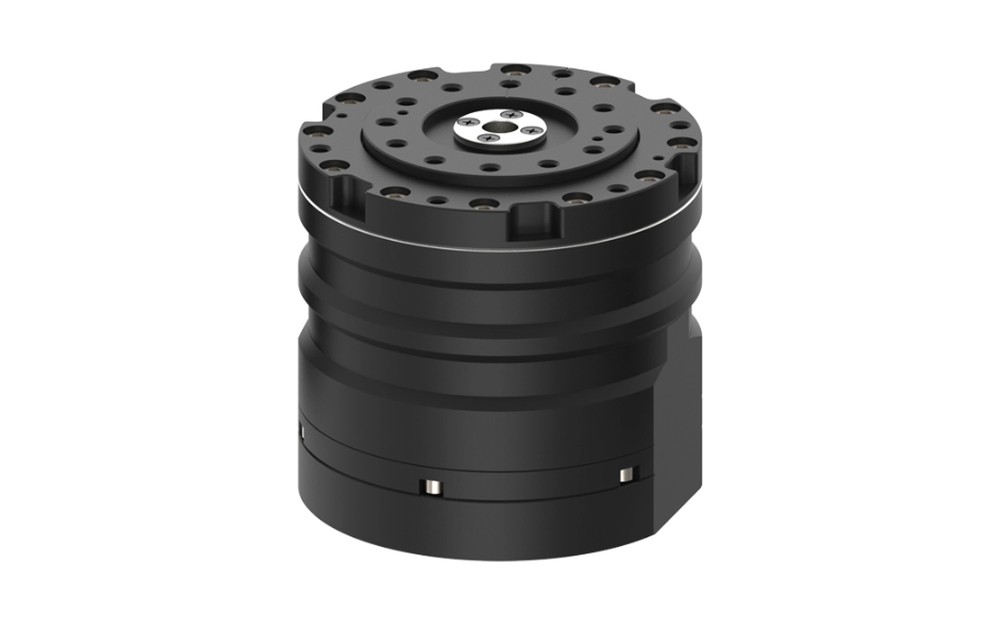
DYNAMIXEL Q
Overview
DYNAMIXEL Q is the ROBOTIS quasi direct drive (QDD) actuator line for humanoids. ROBOTIS highlights its elasticity, strong peak torque and shock absorption.
Position, velocity, torque and impedance control modes are supported.
- 166 N·mPeak torque (QC100)
- 48 VInput voltage
- < 10′Backlash
- 4Control modes
Key Features
Quasi direct drive
QDD actuators with a frameless BLDC motor. Gear ratios are 25:1 on the QC050 and 20:1 on the other QC models.
Four control modes
Position, velocity, torque and impedance control.
Hollow shaft
Hollow shaft sizes range from Ø4 to Ø9 mm, depending on the model.
RS485 bus
RS485 multidrop bus, 9,600 bps to 8 Mbps, with up to 253 IDs.
Encoders
A motor encoder plus a 65,536 pulse/rev output encoder.
Models & Specifications
Specifications
| QC050 | QC060 | QC080 | QC100 | |
|---|---|---|---|---|
| Power | 110 W | 200 W | 240 W | 430 W |
| Continuous torque | 2.5 N·m | 10.6 N·m | 24.2 N·m | 51.6 N·m |
| Maximum torque | 8.0 N·m | 30.0 N·m | 72.6 N·m | 166.2 N·m |
| Continuous speed | 120 rpm | 150 rpm | 95 rpm | 80.3 rpm |
| No load speed | 240 rpm | 200 rpm | 110 rpm | 88 rpm |
| Gear ratio | 25 : 1 | 20 : 1 | 20 : 1 | 20 : 1 |
| Weight | 250 g | 455 g | 865 g | 1,810 g |
| Size (D x H) | Ø46 x 52 mm | Ø58 x 60 mm | Ø78 x 65 mm | Ø98 x 82 mm |
| Hollow shaft | Ø4 mm | Ø5 mm | Ø7 mm | Ø9 mm |
| Continuous / max current | 2.75 / 8.8 A | 6.7 / 19.0 A | 7.5 / 22.5 A | 10.5 / 33.8 A |
Common to all models
| Item | Value |
|---|---|
| MCU | ARM Cortex-M33, 250 MHz |
| Motor | Frameless BLDC |
| Input voltage | 48 V |
| Backlash | < 10 arcmin |
| Operating temperature | -5 to +55 °C |
| Communication | RS485 multidrop, 9,600 bps to 8 Mbps |
| IDs | 253 (0 to 252) |
| Standby current | 13 mA |
Specifications are preliminary and may change.
Where it fits
- Humanoid robots
- Dynamic balancing and manipulation (as described for AI Sapiens)