Robotclub Malaysia › Ecosystem › OMX / OMY
Open Manipulator OMX / OMY
The Ai Manipulators for Physical AI: OMX is good for beginners, OMY is more suitable for research and automation.
AI manipulators
Overview
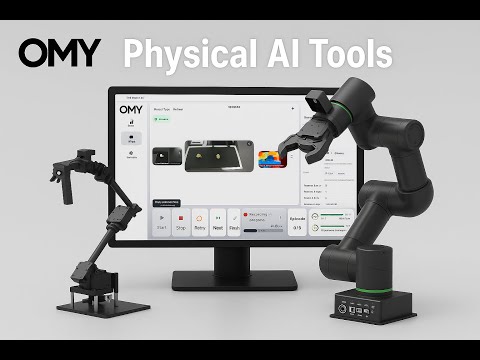
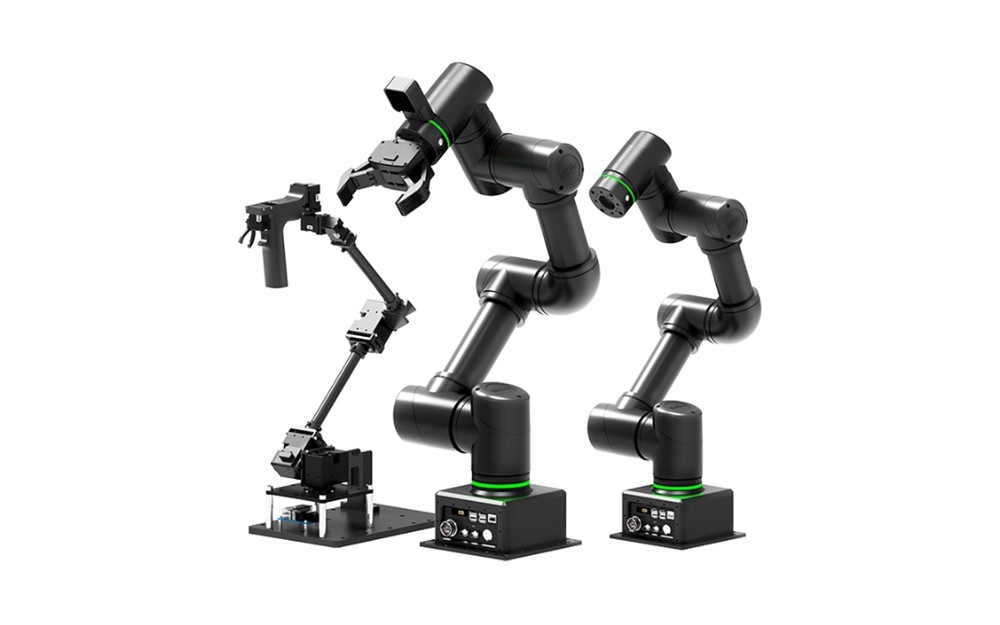
OMX is a compact 5 DOF Physical AI manipulator built on DYNAMIXEL X. ROBOTIS describes it as designed for hands on dataset collection, with ROS 2 native workflows and support for end to end imitation learning and reinforcement learning pipelines.
OMY is a 6 DOF manipulator built with DYNAMIXEL Y actuators for Physical AI research and intelligent automation. ROBOTIS lists pick and place, assembly and inspection in academic, industrial and development settings, and it is ROS 2 compatible.
Robotclub Malaysia is Offical Distributor of OMX/OMY in Malaysia,we have used this platform in various robotics projects.
- 5DOF on OMX
- 6DOF on OMY
- ROS 2Native support
- IL + RLLearning workflows
Key Features
OMX: plug and play
Motor parameters are set and every actuator is calibrated at the factory, so you can connect and start. It also works with LeRobot.
OMX: safe homing and 360° base
The follower arm can safely return to its start pose from any position, and the base rotates a full 360°.
OMX: leader arm
The leader has a low friction design and a spring assisted trigger. The OMX-L leader runs from a single USB-C connection, and ROBOTIS notes that even children can control it safely.
OMY: skill acquisition by demonstration
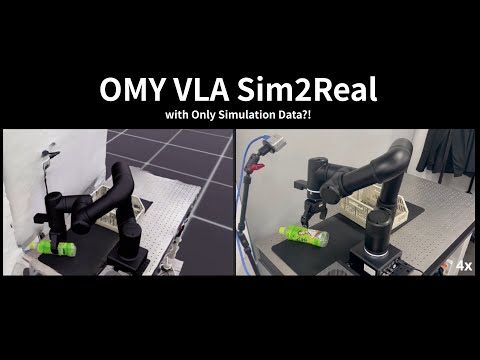
New tasks are taught by demonstration, without extensive programming.
OMY: DYNAMIXEL Y actuators
High torque, high resolution actuators across six degrees of freedom, for accurate and repeatable manipulation.
OMY: modular and ROS 2 native
A modular structure for adding sensors and tools, with ROS 2 support for real time control.
Models & Specifications
Specifications
| OMX | OMY | |
|---|---|---|
| Described by ROBOTIS as | Physical AI manipulator for dataset collection | Physical AI research manipulator for intelligent automation |
| Degrees of freedom | 5 | 6 |
| Actuators | DYNAMIXEL X | DYNAMIXEL Y |
| Software | ROS 2 native | ROS 2 native |
| AI workflow | ROBOTIS Physical AI Tools and LeRobot | End to end imitation learning pipeline |
| Teleoperation | Leader follower; leader powered by USB-C | Leader follower with collision aware motion and gravity compensation |
| Typical tasks | Dataset collection and policy learning | Pick and place, assembly, inspection |
Where it fits
- Collecting demonstration data for imitation learning (OMX)
- Pick and place, assembly and inspection (OMY)
- Labs, classrooms and automation setups (OMY)